Spidey & Armie
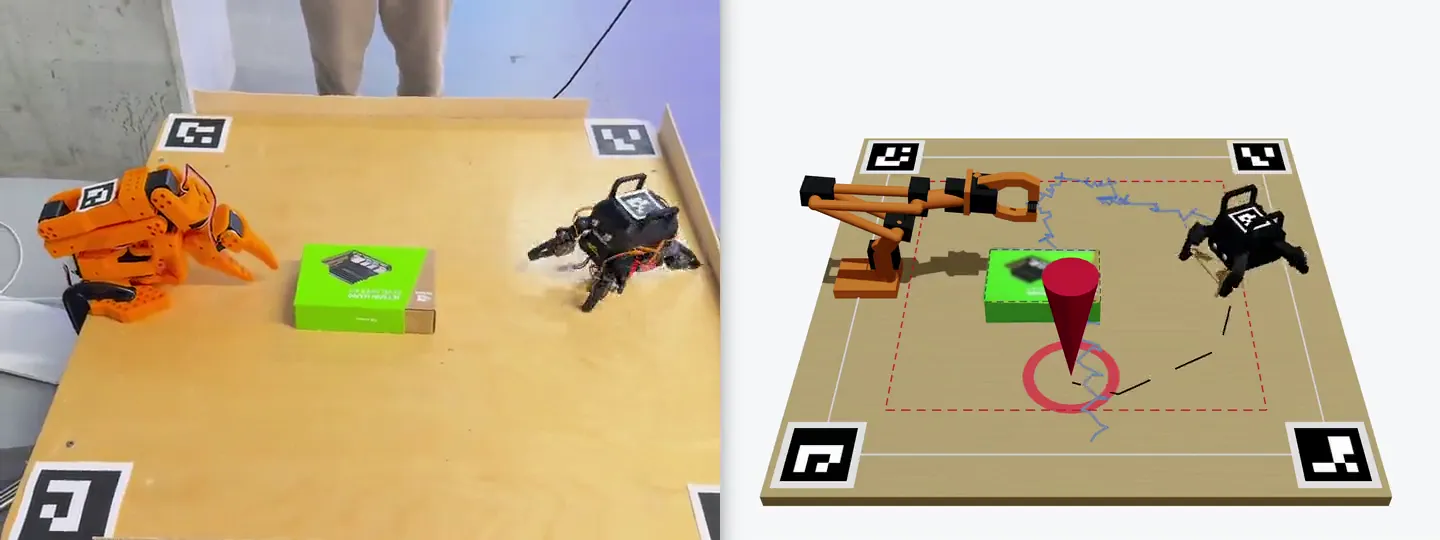
3d twin that steers a real robot
A live 3D reconstruction of a robot table: click anywhere and the real four-legged robot walks there, and when obstacles block every path, a robot arm carries it past. Built at Hack the North 2026 with three teammates. I built the tracking and navigation that keep it in sync: a C++ camera tracker on a QNX Raspberry Pi, MobileSAM object detection, and path planning.
C++ · TypeScript · OpenCV
github.com/aicheye/HTN26